MotionBridge | Where Digital Scenes and Real World World Physics Converge
SANLAB’s custom 6DOF emulator integrates motion platforms with Unreal Engine for precise real-time simulation feedback.
Discover the power of 6DoF (Six Degrees of Freedom) in robotics, and learn how motion across six axes transforms modern automation, simulation, and engineering design.
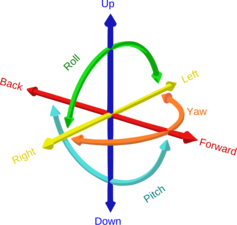
When we talk about 6DoF, or Six Degrees of Freedom, we’re describing a system’s ability to move in all possible directions within three dimensional space.
A robotic arm, a flight simulator, or a motion platform that supports 6DoF can perform movements along and around all three spatial axes (X, Y, and Z), combining both translation and rotation.
In robotics and mechatronics, 6DoF isn’t just a number; it’s the foundation of true spatial freedom.
Whether you’re stabilizing a drone in flight or simulating vehicle dynamics in a training setup, 6DoF motion enables realistic, physically accurate movement that enhances both performance and user immersion.
6DoF systems are built on mechanical architectures that allow independent yet coordinated movement across all six axes.
These are often powered by
actuators, servo motors, and sensors, integrated through advanced control algorithms.
Modern control systems rely on a mix of PID controllers, model-based planning, and sensor fusion.
This ensures that motion is not only accurate but also safe and responsive, even under variable load conditions.
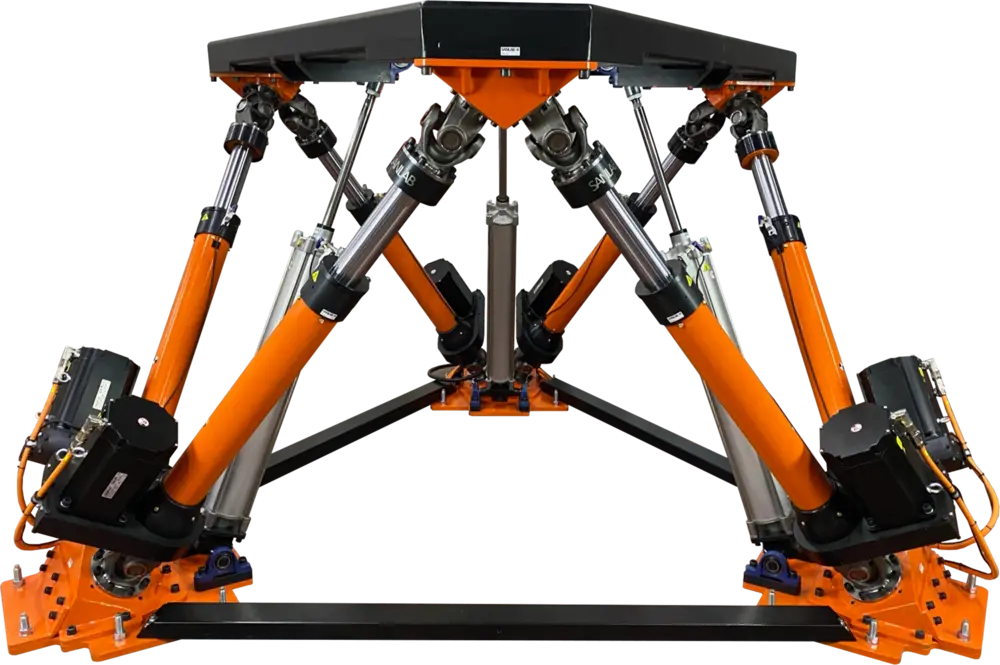
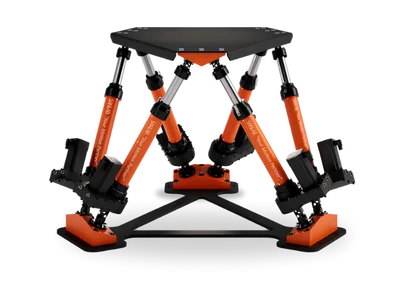
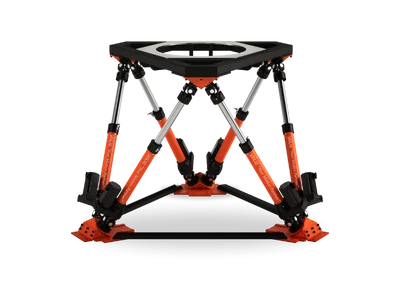
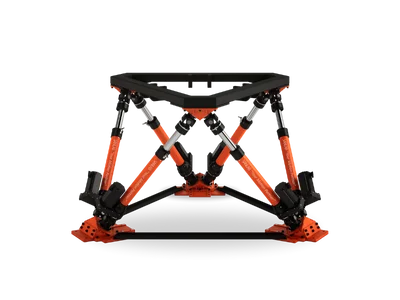
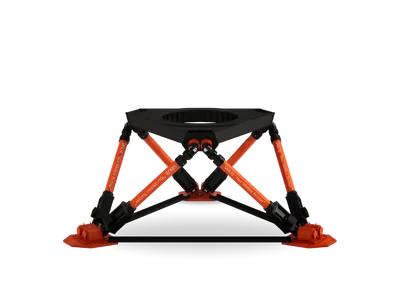
A 6DoF robotic arm is a serial mechanism: its joints sit one after another, so each joint carries every joint beyond it, and the end effector can reach far around the base. A Stewart platform reaches the same six degrees of freedom with a parallel mechanism. Six linear actuators, usually called legs, connect a fixed base to a moving top plate, and all six carry the load at the same time.
Because of those six legs, the Stewart platform is also called a hexapod or hexapod platform, and in simulation a 6DoF motion platform or motion base. Gough, Cappel and Stewart are all credited with the design, which is why the name Gough-Stewart platform is also in use.
Each leg is mounted to the base and to the top plate through joints that let it pivot, so a leg can only push or pull along its own line. To reach a target pose, the controller calculates the six leg lengths that produce it. This is the platform’s inverse kinematics, and for a Stewart platform it can be solved directly for every pose.
When the six legs change length together, the top plate translates in surge, sway and heave and rotates in roll, pitch and yaw. The difficult direction is the reverse: working out the plate’s pose from six known leg lengths, the forward kinematics, has several possible solutions and is solved numerically. It is the opposite of a serial arm, where forward kinematics is the straightforward calculation.
Stiffness and load: the six legs share the payload, so a hexapod platform stays stiff and carries heavy loads for its size.
Coupled axes: travel in one axis depends on the position of the others, which is why hexapod travel is published both per single axis and for combined motion.
Limited workspace: the top plate moves inside a bounded envelope and cannot rotate continuously. Unlimited rotation needs an added rotator or turntable.
Reach: a serial arm covers a far larger workspace around its base, which is why it suits pick-and-place and assembly work.
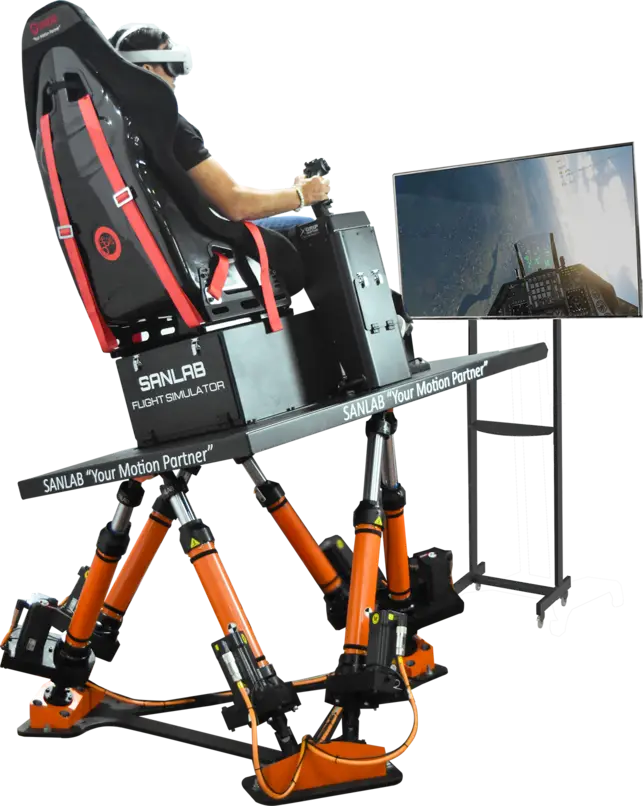
The same architecture serves two kinds of work. In precision positioning and testing, a hexapod platform puts sensors, antennas, electro-optical units and other test articles into exact, repeatable poses. In motion simulation, it reproduces the motion of vehicles, aircraft and vessels under a cockpit or a test rig.
SANLAB designs and builds 6DoF Stewart platforms (hexapods) from 50 to 14,000 kg payload for both, from the compact 50 to 200 kg class up to the heavy class used in defense systems testing.
The versatility of 6DoF technology has led to its widespread use across multiple industries.
Flight simulators, vehicle training systems, and industrial safety simulators rely heavily on 6DoF motion platforms to replicate real physical sensations.
6DoF robotic arms handle assembly, inspection, and packaging with unmatched precision, enabling more flexible automation in manufacturing.
6DoF setups allow researchers to test dynamics, vibration, and stability in controlled yet realistic conditions from vehicle motion to aerospace systems.
Building a precise 6DoF platform is a complex engineering challenge that combines mechanical design, control theory, and real-time software integration.
After understanding the principles of Six Degrees of Freedom, it becomes clear how these concepts are shaping next-generation robotics and motion systems.
6DoF-based simulators are now used in industrial training, vehicle testing, and advanced research, bridging the gap between theoretical design and real-world performance.
This is where advanced motion technology providers step in engineering systems that combine precision, realism, and intelligent control.
Below is a quick look at some 6DoF motion systems designed for various professional and educational applications.
6DoF (Six Degrees of Freedom) defines how motion becomes reality in robotics, simulation, and automation.
If you want to see how 6DoF motion technology can elevate your training, research, or industrial applications Explore our motion platforms and discover freedom in every direction.
It’s what allows systems to move like humans, respond like machines, and perform beyond limitations.
SANLAB’s custom 6DOF emulator integrates motion platforms with Unreal Engine for precise real-time simulation feedback.
SANLAB joined techUK; Co-founder Evren Emre was nominated for the People Award at techUK Annual Dinner 2025.
SANLAB hosted University of Colorado Boulder MBA group for a session on entrepreneurship, business, and technology.
SANLAB hosted Penn State MBA students for discussions on robotics, training technologies and innovation in tech sectors.
SANLAB’s custom 6DOF emulator integrates motion platforms with Unreal Engine for precise real-time simulation feedback.
SANLAB to participate in ERF 2025, showcasing Turkish innovation in robotics and AI for a stronger Europe.